Blog
Field notes on building robot skills, from your first teleoperated demonstration to a deployed policy.
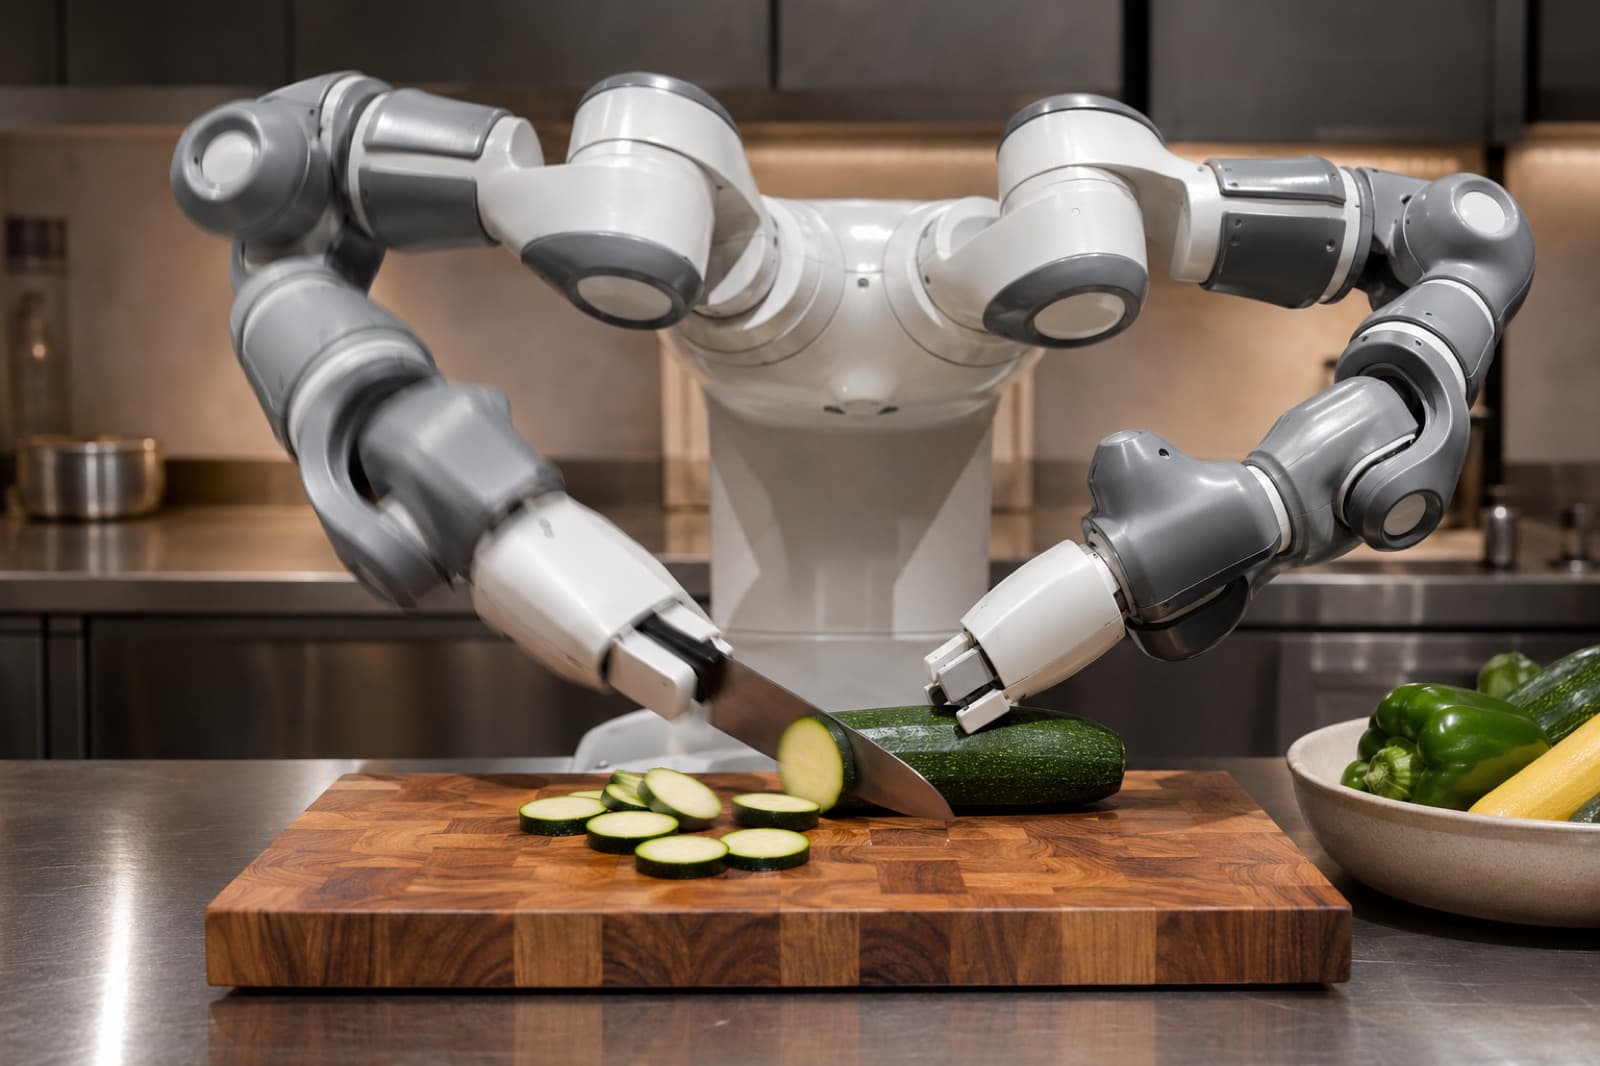
What is Physical AI?
AI that perceives and acts in the real world, and how imitation learning, reinforcement learning, and robotics fit together.
Read the post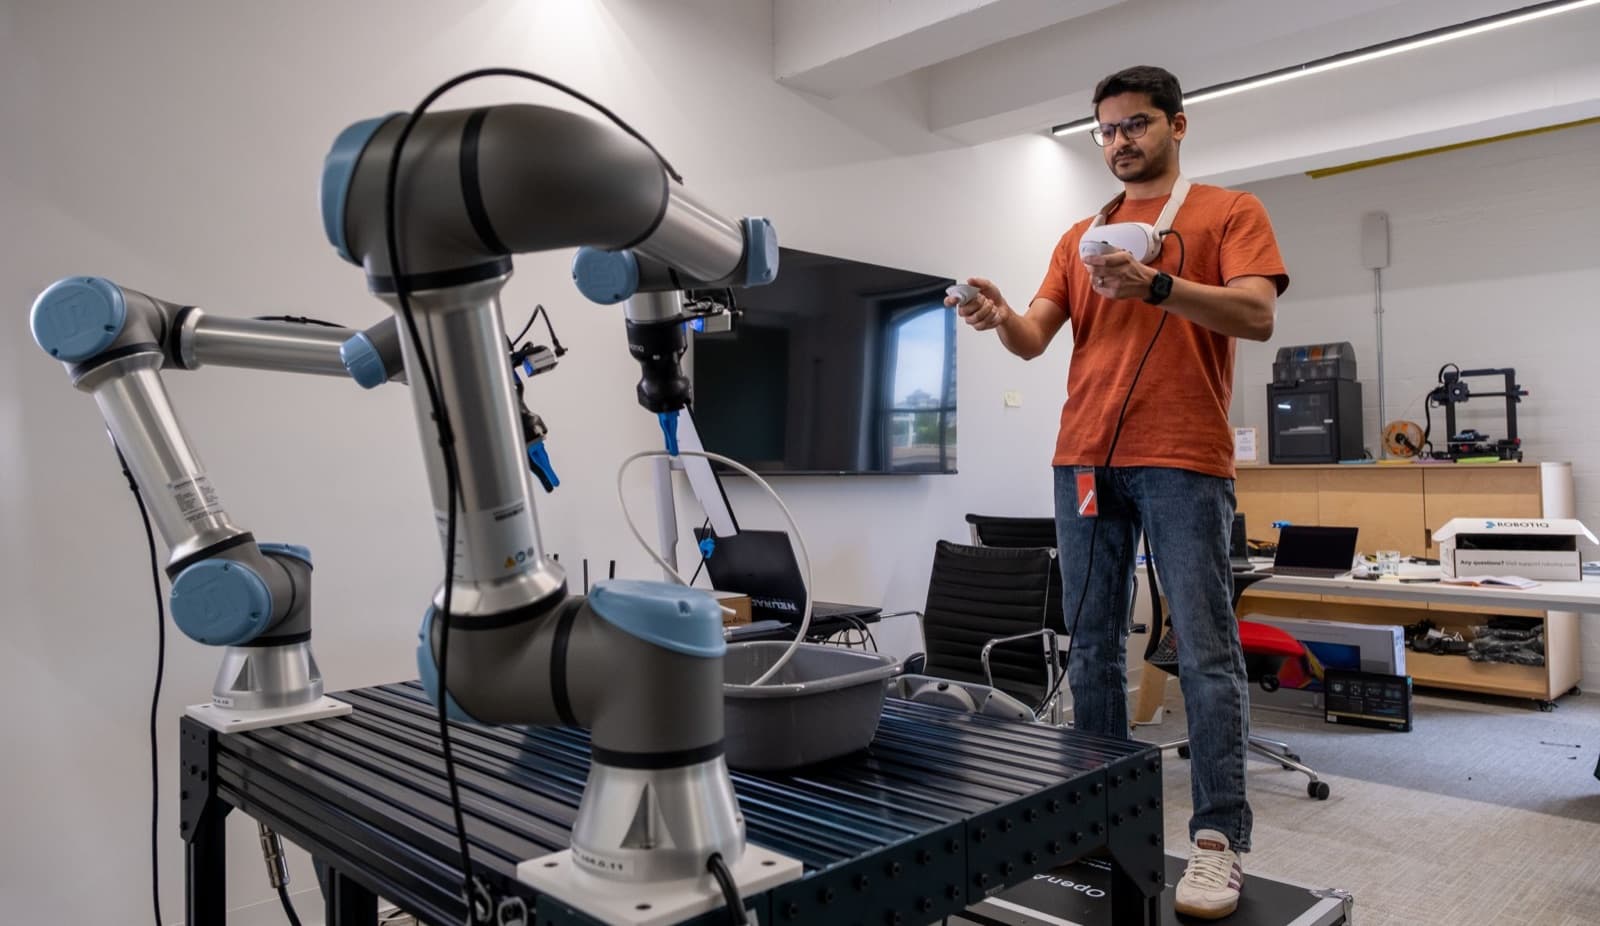
The best teleoperation system for robot data collection
What makes a teleoperation data collection system good, how the main rigs compare, and how to make the data trainable.
Read the post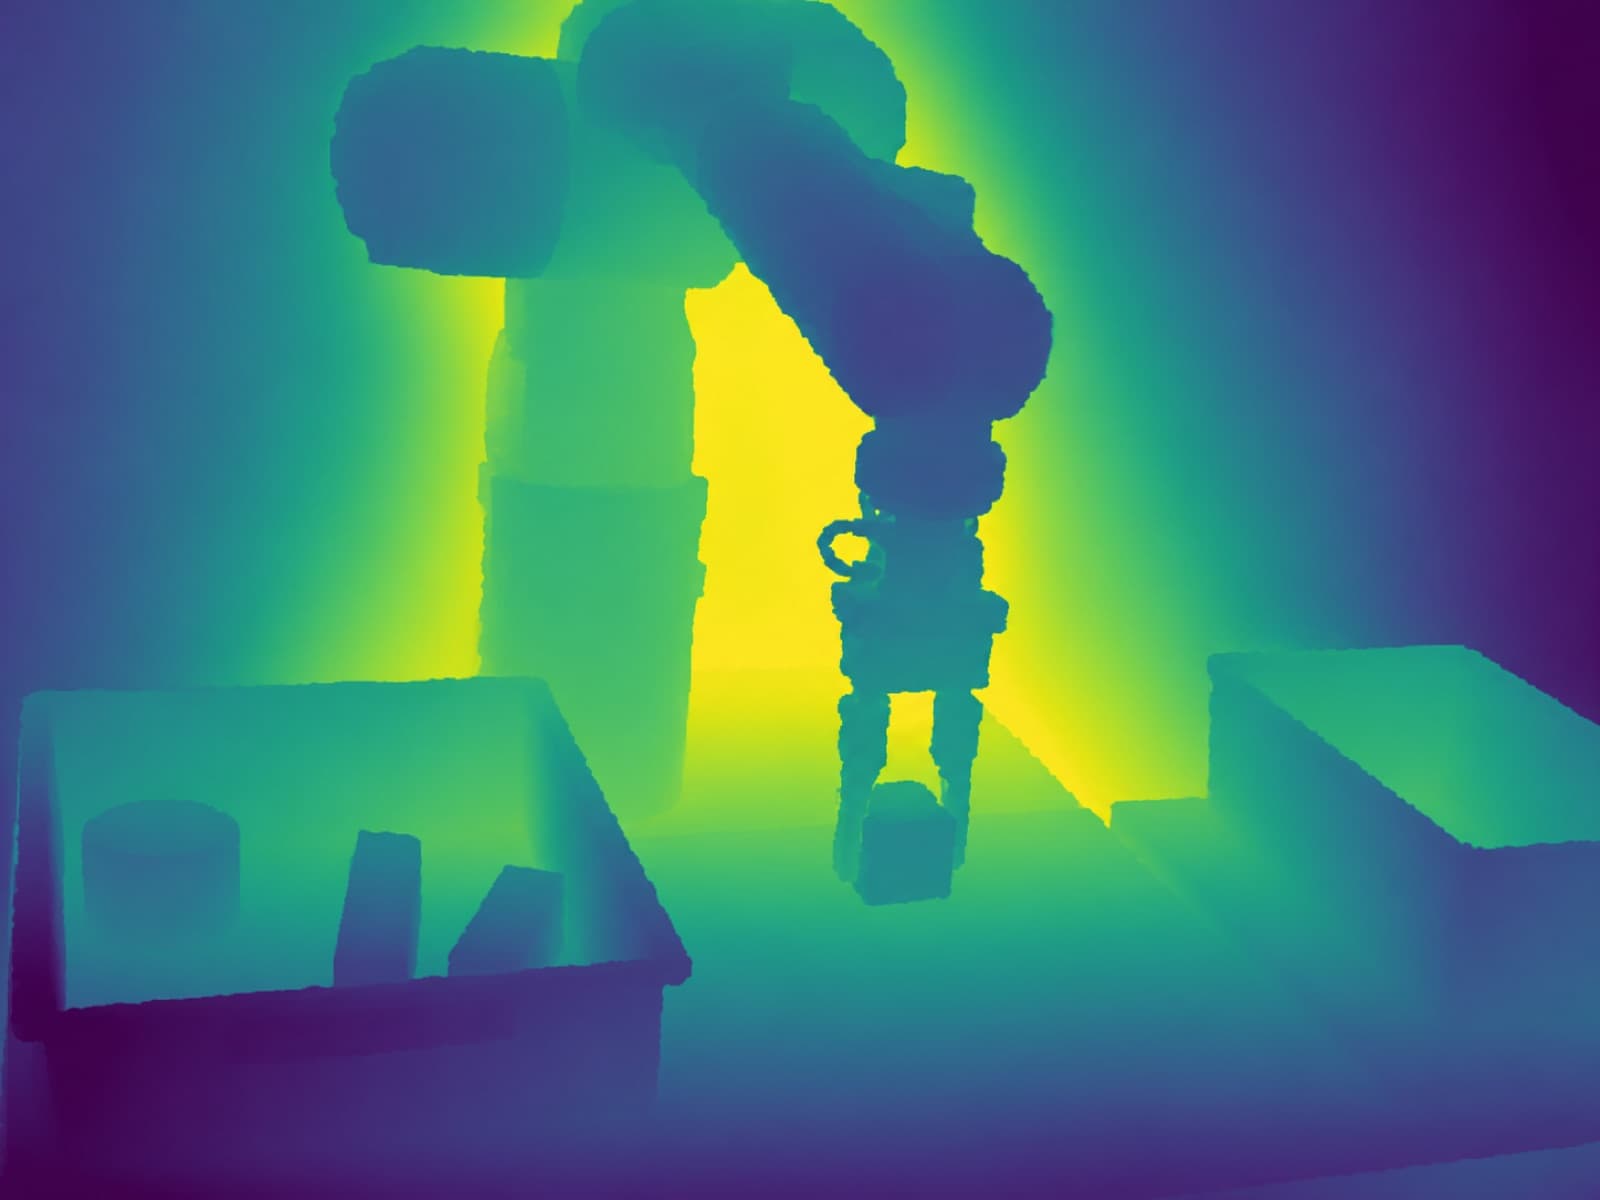
RGB vs. depth cameras for robot skill training
What RGB and depth cameras each capture, where each fails, and which your manipulation policy actually needs.
Read the post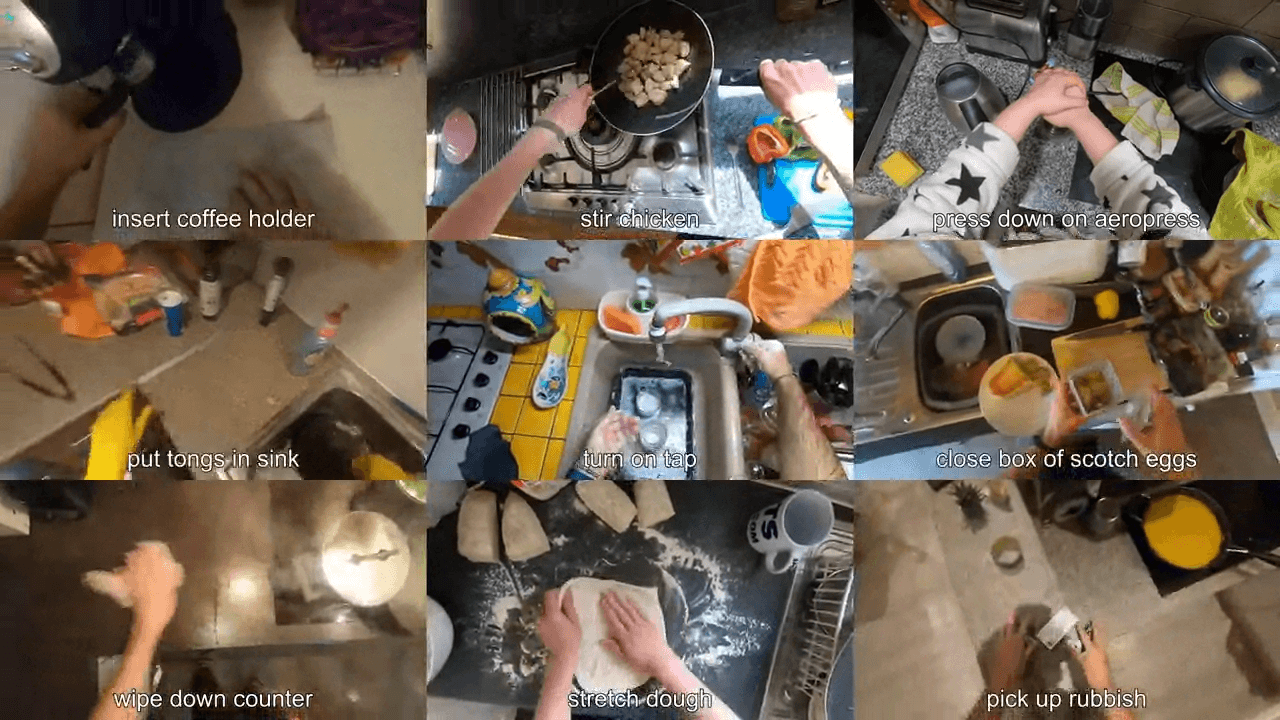
What is a Vision-Language-Action (VLA) model?
How VLA models map camera frames and language instructions straight to robot actions, and where they fit.
Read the post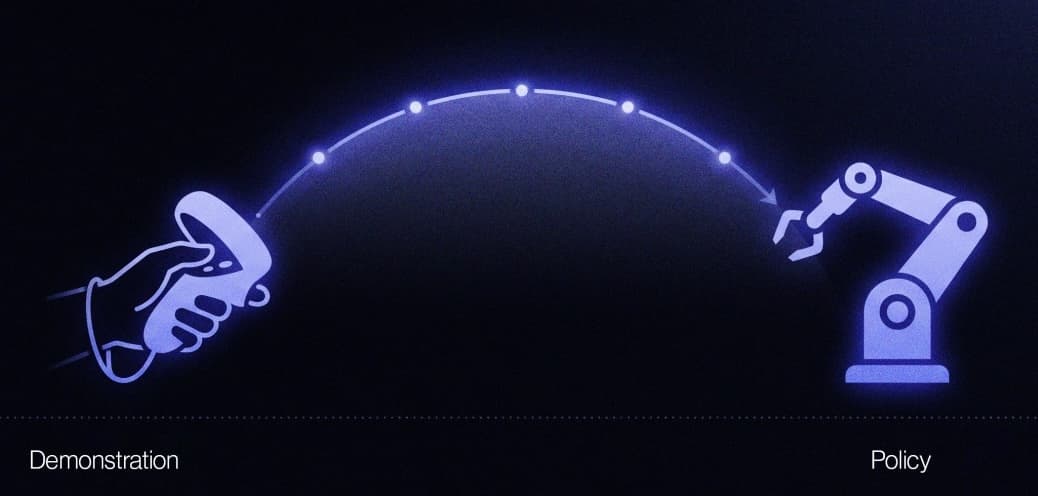
Imitation learning vs. reinforcement learning
When to clone demonstrations, when to reward-optimize, and why most policies use both.
Read the post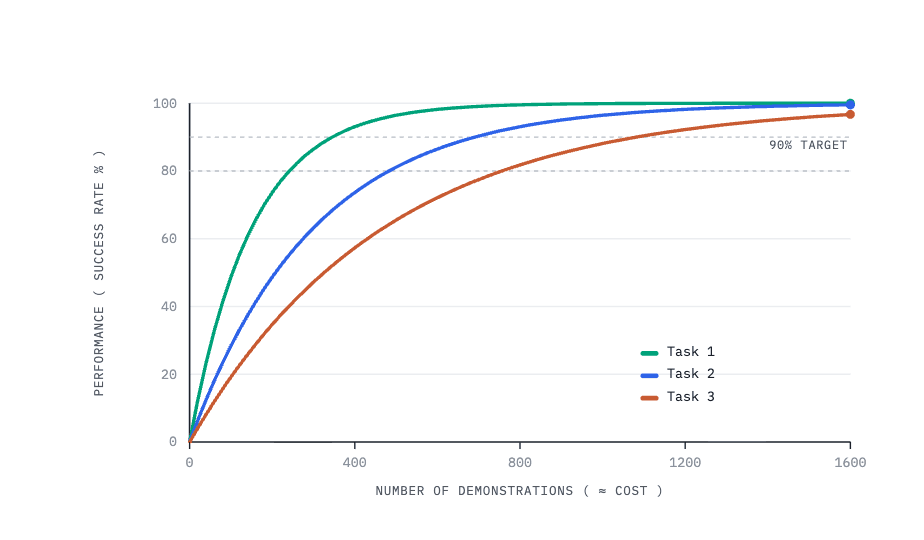
Robot skill scaling laws
How success rate scales with demonstrations, and what a new skill really costs in data and compute.
Read the post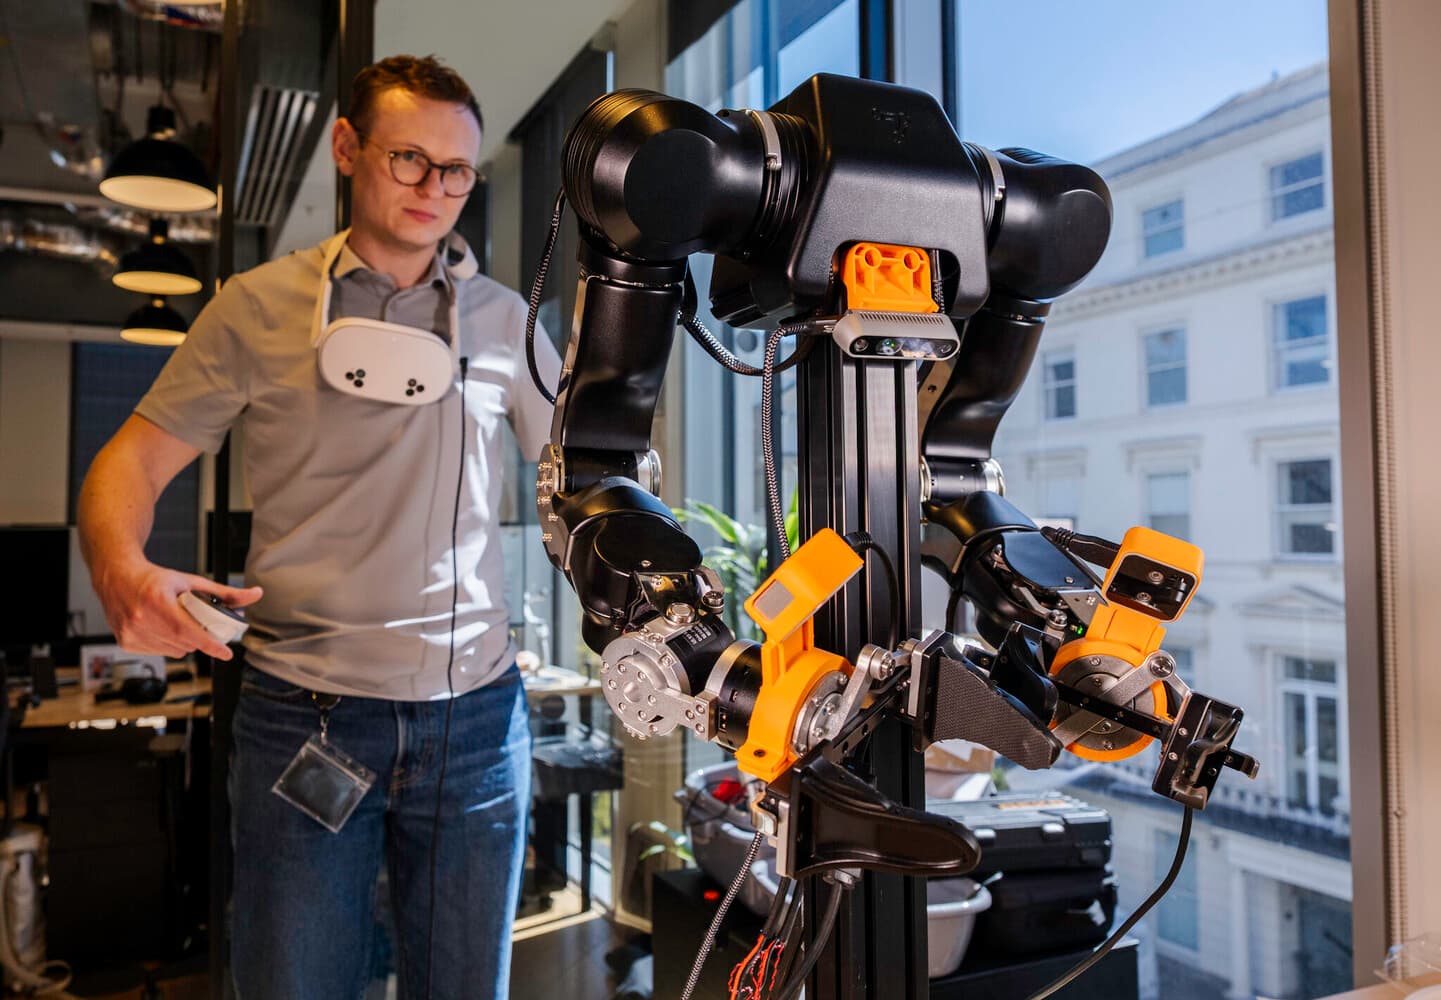
How robot data collection actually works
Teleoperation rigs, what a demonstration actually records, and how to keep the data trainable.
Read the post
Sim-to-real: mixing simulated and real data
How much simulation helps, where it breaks, and how to blend sim and real rollouts.
Read the post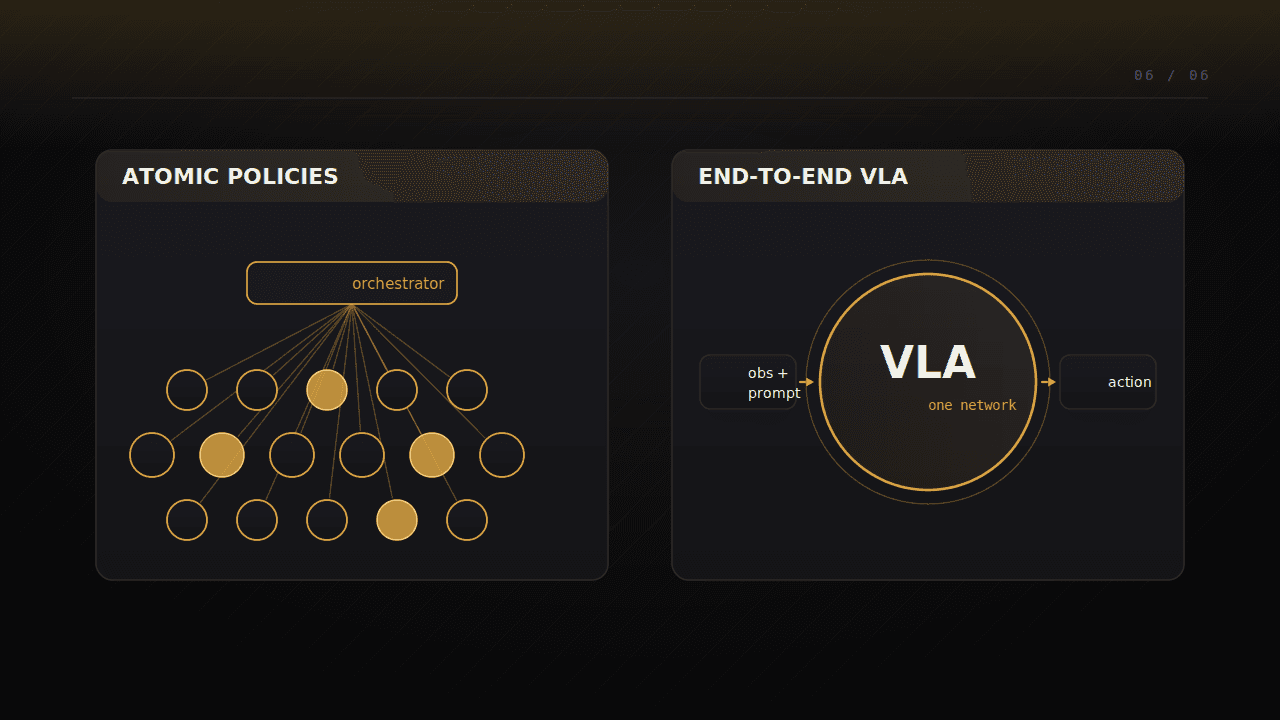
Atomic policies vs. end-to-end VLA models
Short, composable skills or one big model? The tradeoffs in reliability, data, and debugging.
Read the post